Oberseminar "Dynamische Systeme und Kontrolltheorie" -Mengjiao Zhang
Affine systems on Lie groups and control sets
| Datum: | 13.11.2026, 14:15 - 15:15 Uhr |
| Kategorie: | Veranstaltung |
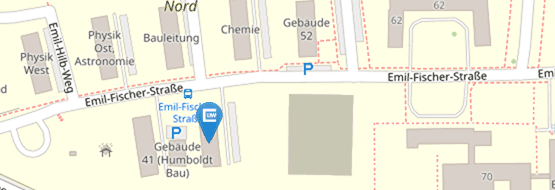
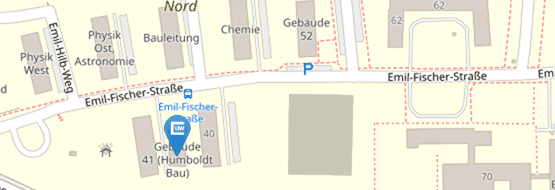
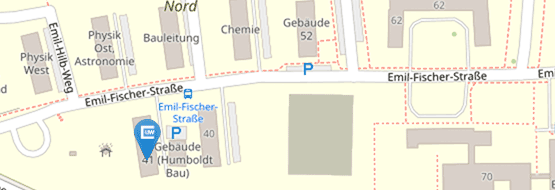
| Ort: | Hubland Nord, Geb. 40, 01.003 |
| Vortragende: | Mengjiao Zhang, Nankai University, China |
This talk presents my recent research on prescribed-time safety control for multi-agent systems subject to multiple constraints. The objective is to ensure that agents enter a desired safe set within a prescribed time while satisfying obstacle avoidance, collision avoidance, and control input constraints.
To achieve this, a continuous lower-bound-based control barrier function is developed and incorporated into a distributed CBF-CLF quadratic programming framework. A local feasibility condition is also established to characterize the compatibility of the prescribed-time safety requirement with other safety constraints. The theoretical results are illustrated through numerical simulations involving multiple agents and densely distributed obstacles.